Nanotree
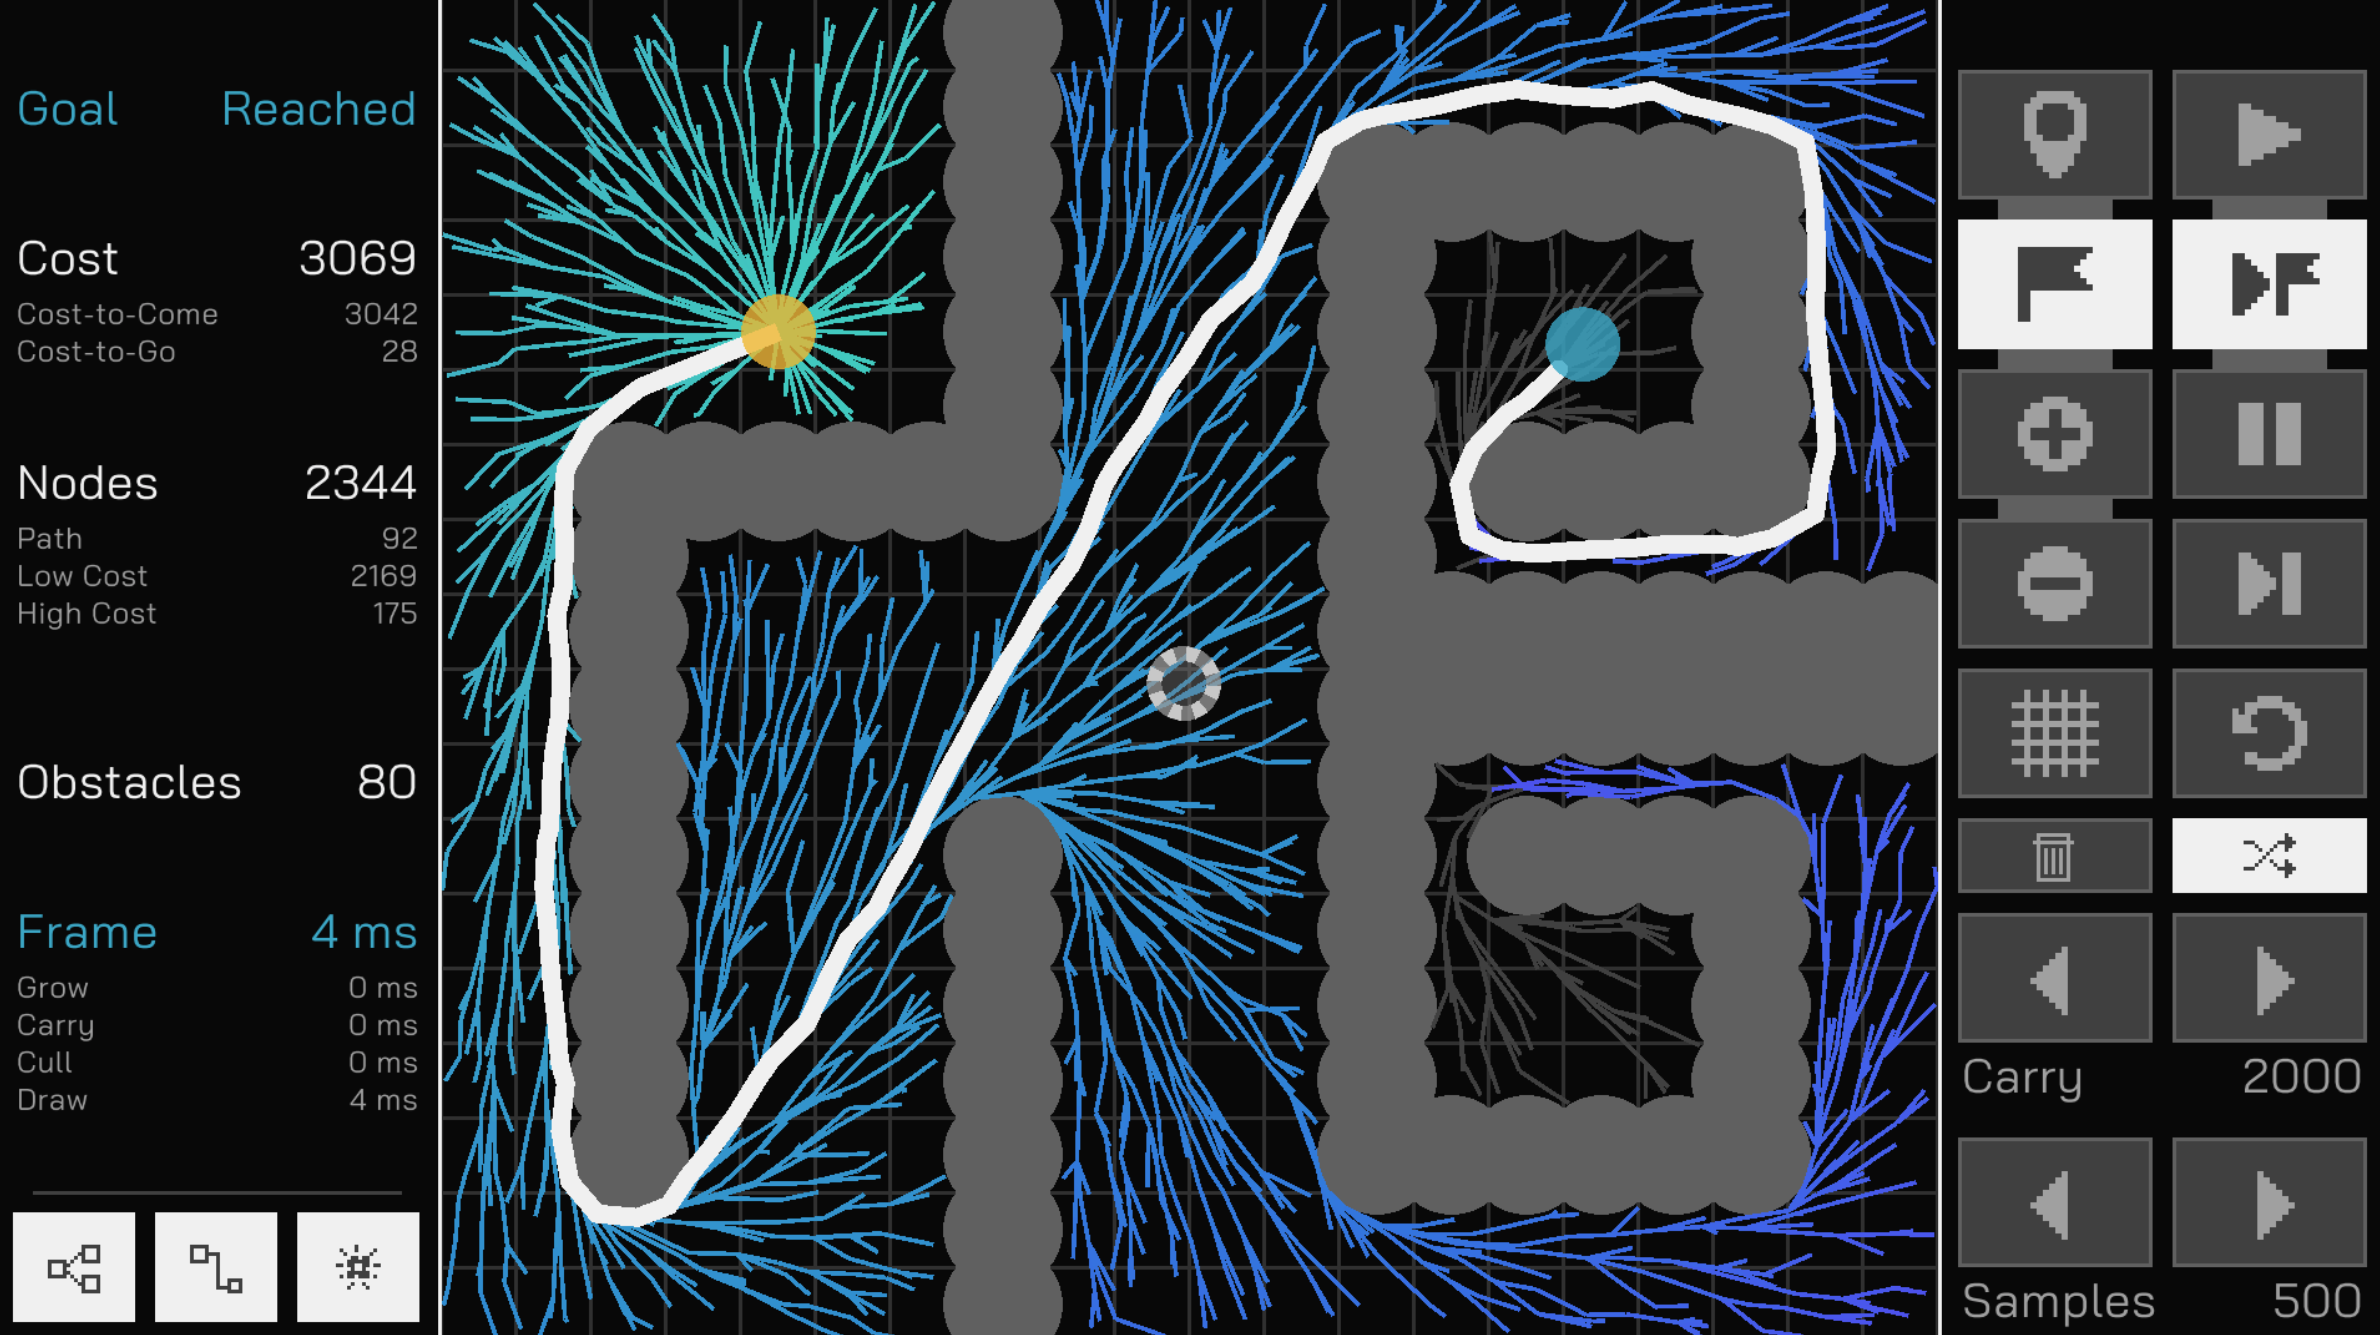
Sampling-based path planning using a modified RRT* algorithm.
Treetop
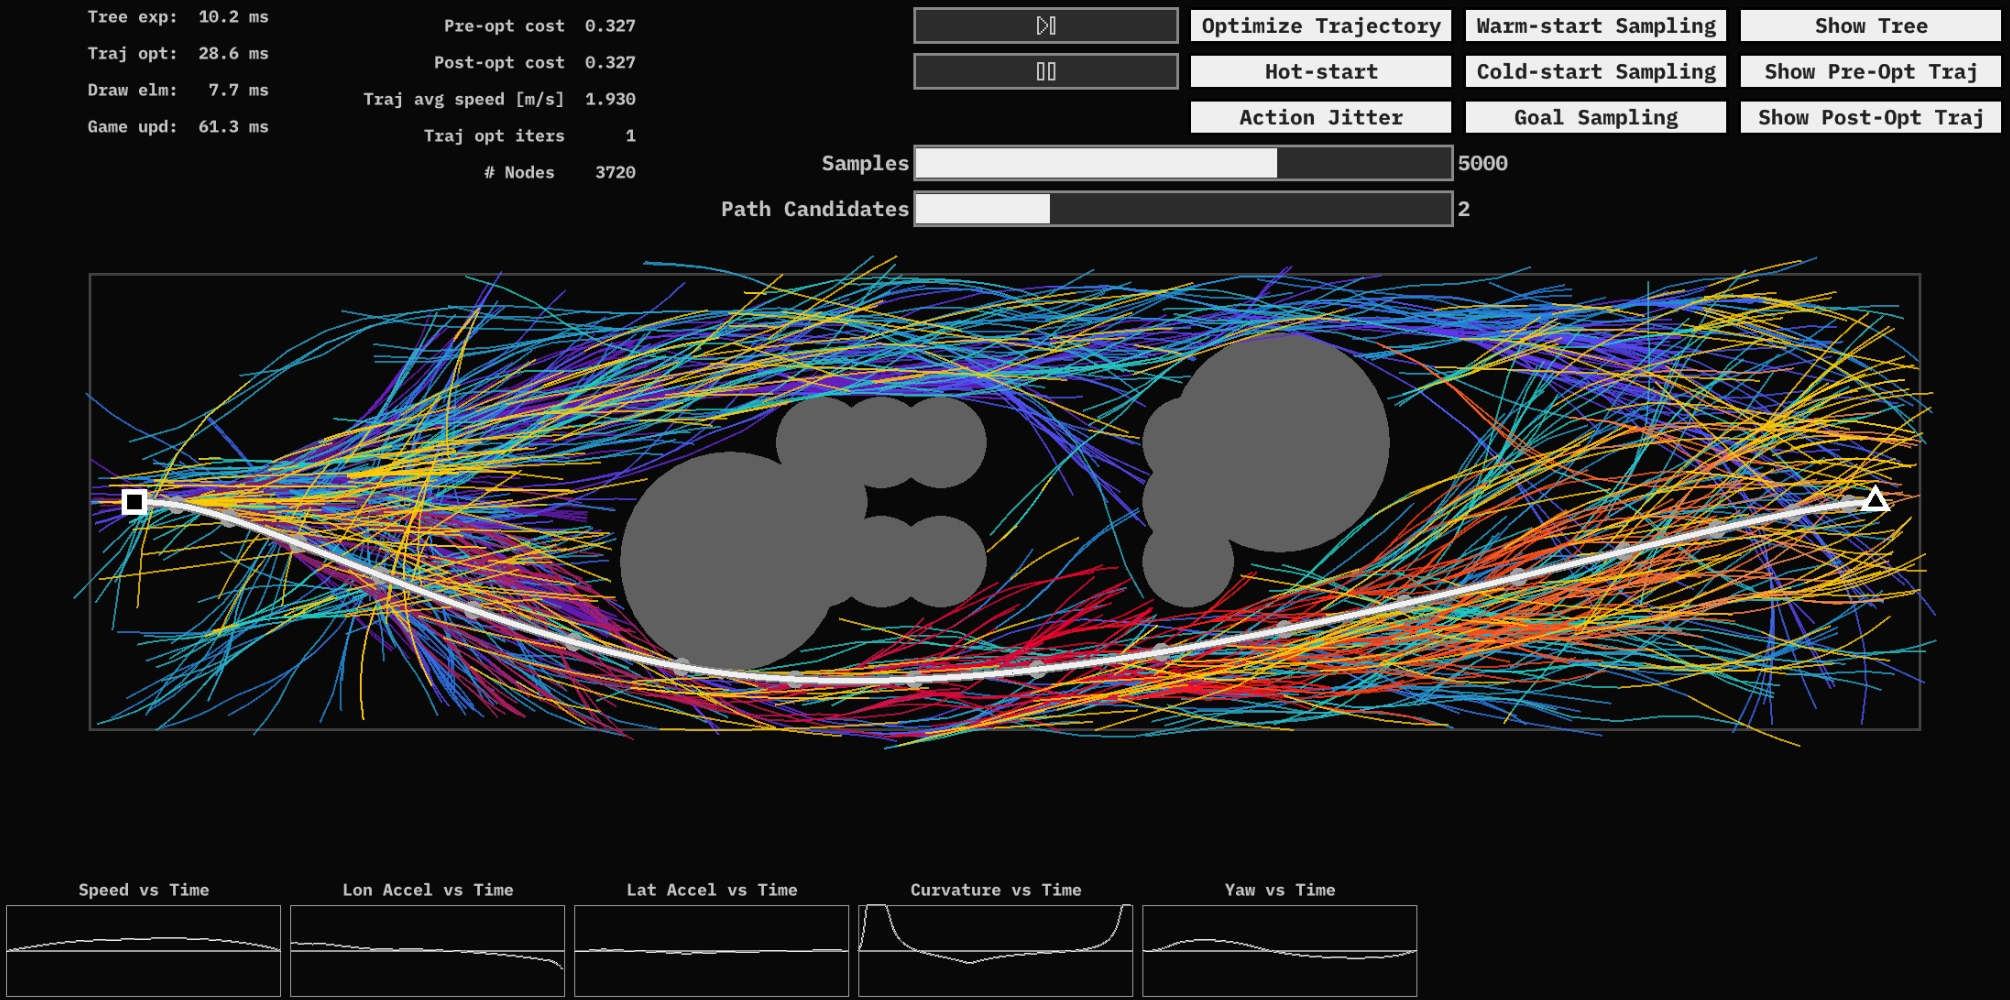
Sampling-based tree expansion and gradient-based trajectory optimization for a car-like vehicle.
Cartpole Optimal Control
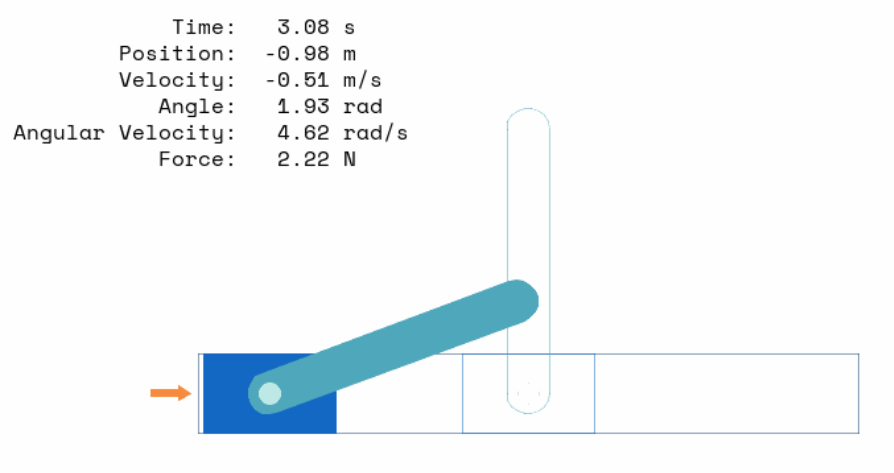
Learn about optimal control through the classic cartpole swing-up problem.
Terra
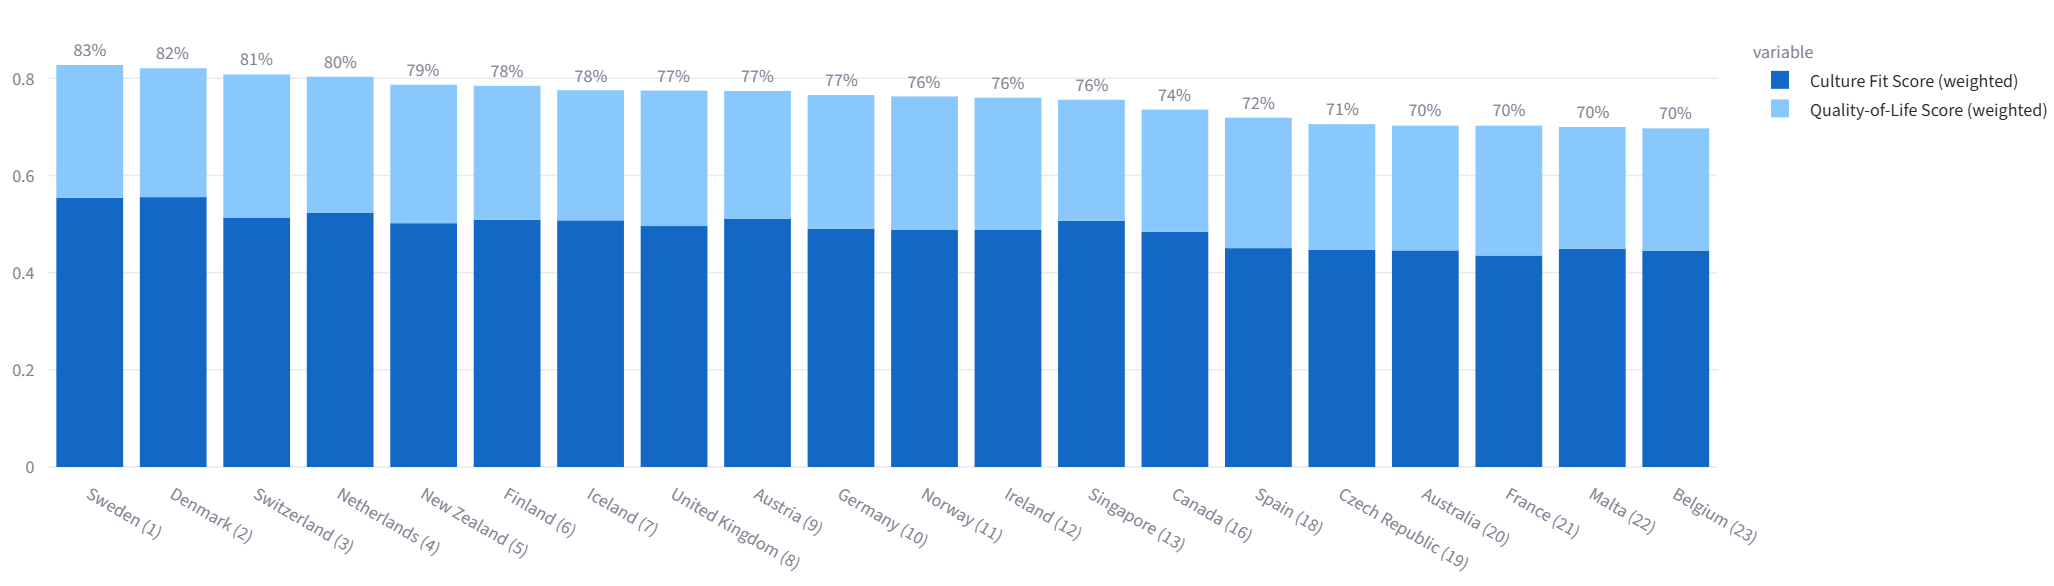
Answer "which country is right for me?" using data-driven recommendations tailored to your preferences.
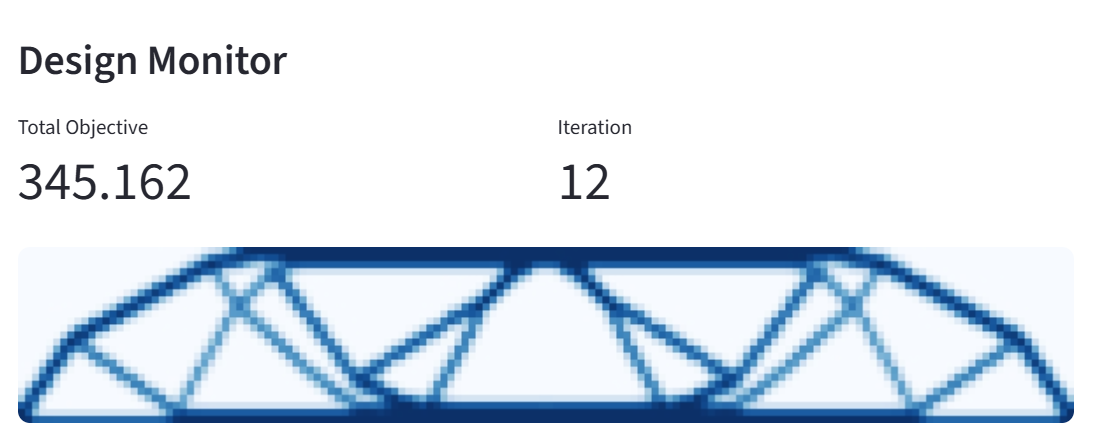
Structura
Find the most efficient material layout for a given load case.
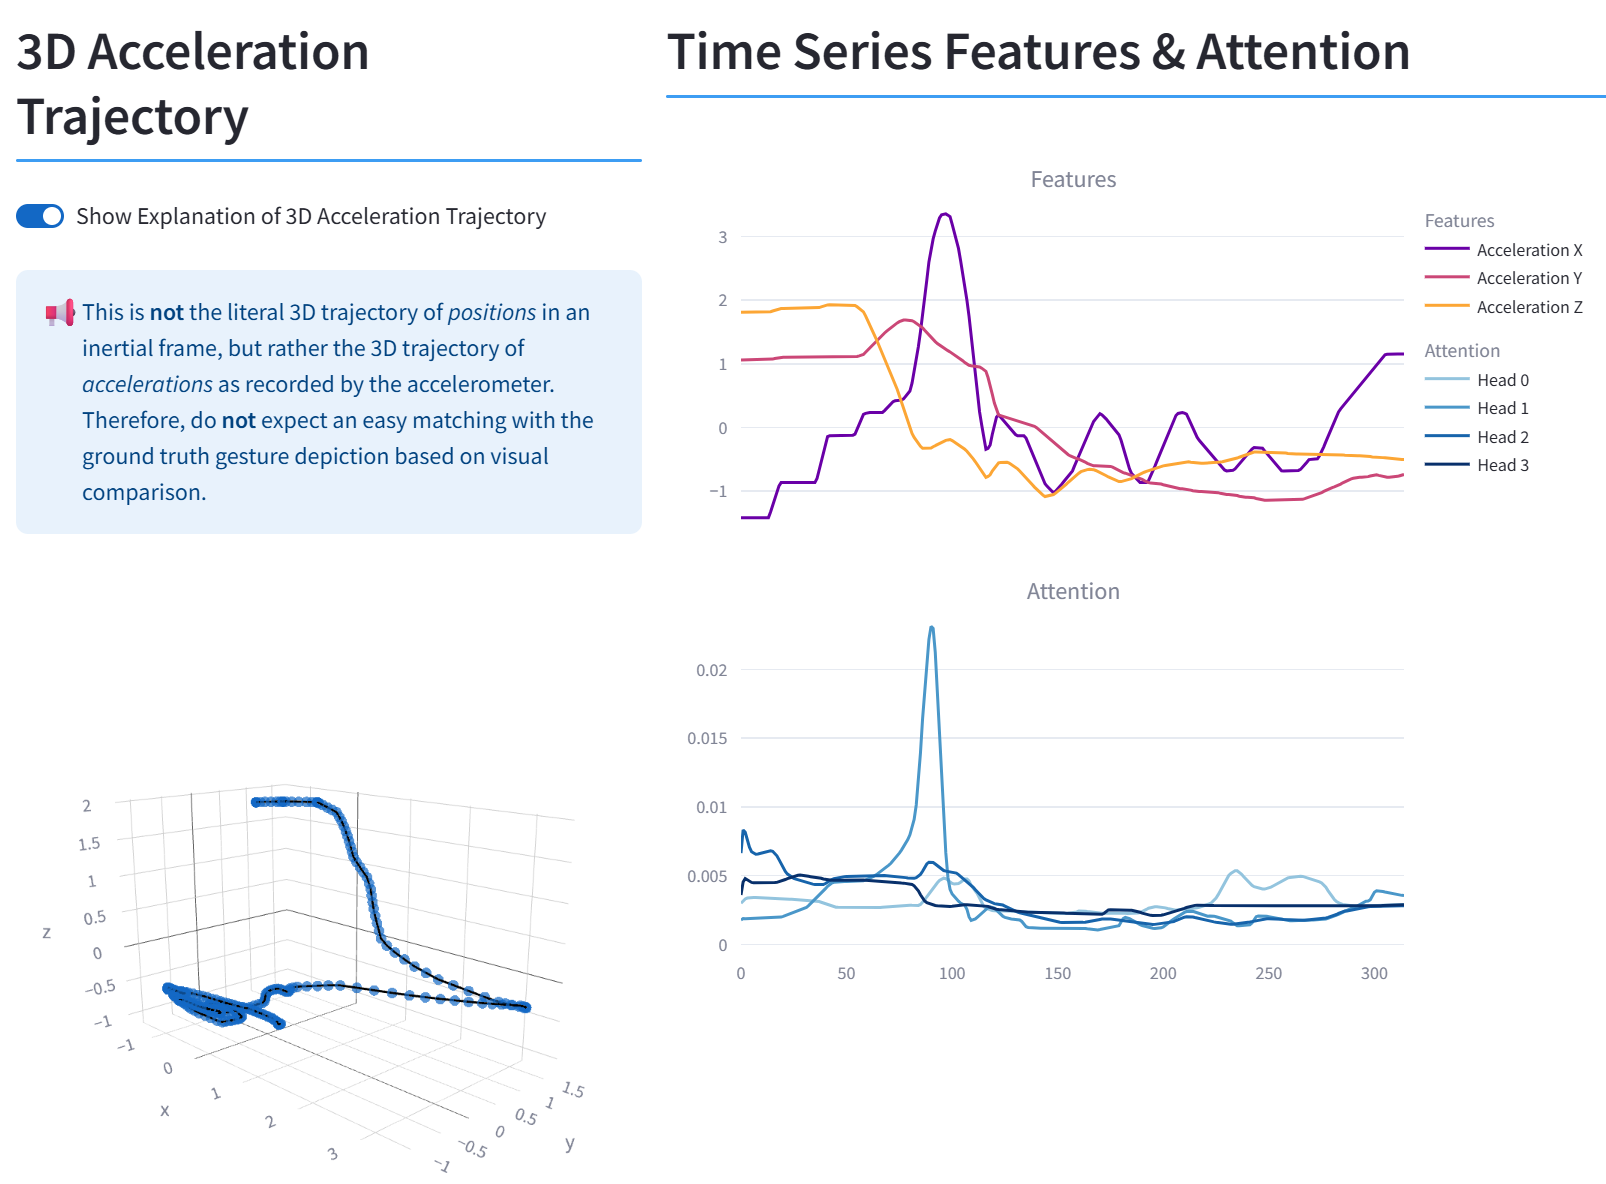
Gestura
Live predictions from a deep neural network trained to classify gestures from raw time-series sensor data.
Mosaic Maker
Create mosaics by tiling thousands of images to reconstruct a target picture.
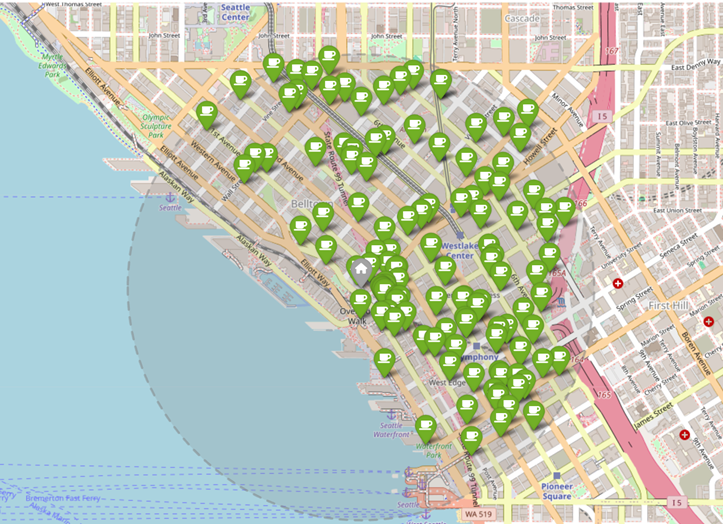
Coffee Finder
Discover coffee shops in your area using location-based search.